Sakana AI's SAIL Triples Robot Success Rates by Searching Before Moving
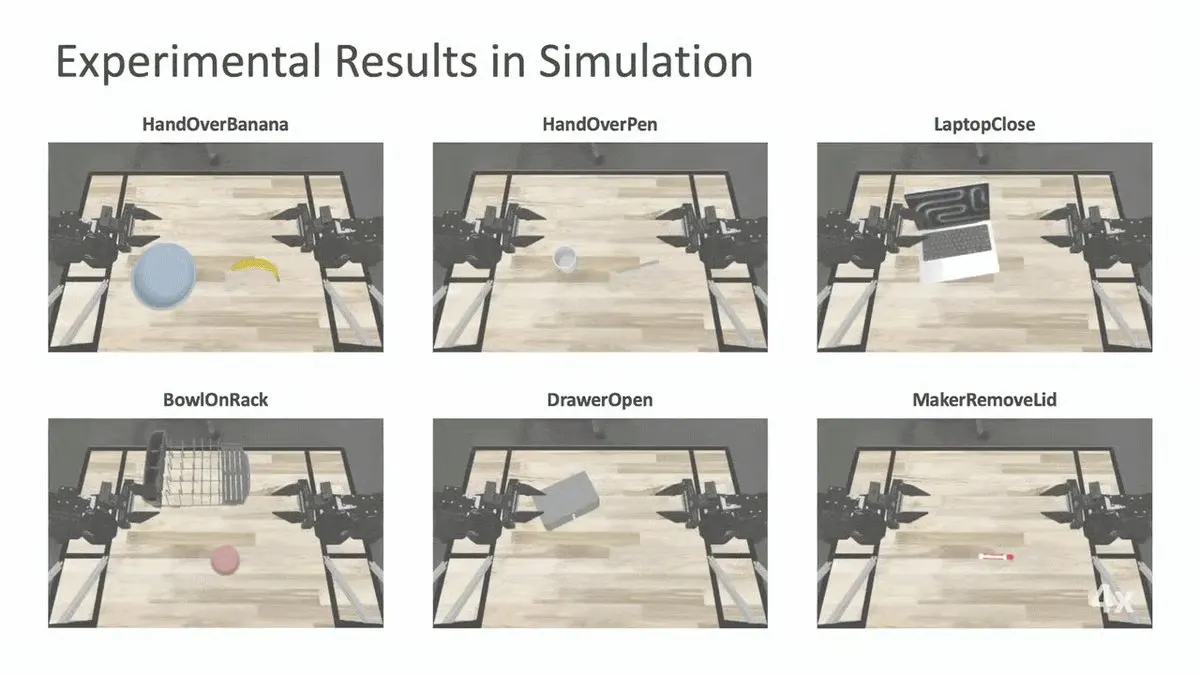
Sakana AI and the University of Tokyo show that a vision language model can plan robot motions more reliably by testing and refining candidate trajectories in simulation before touching the real robot.
Source
Sakana AI
Published
Author
AlphaSignal Newsroom
Read
1 min read
Sakana AI and the University of Tokyo show that a vision language model can plan robot motions more reliably by testing and refining candidate trajectories in simulation before touching the real robot.
Reporting is indexed from AlphaSignal. Rights remain with the original publisher and cited sources.