Georgia Tech's MO-Playground Trains Robots 271x Faster With Open-Source GPU Tool
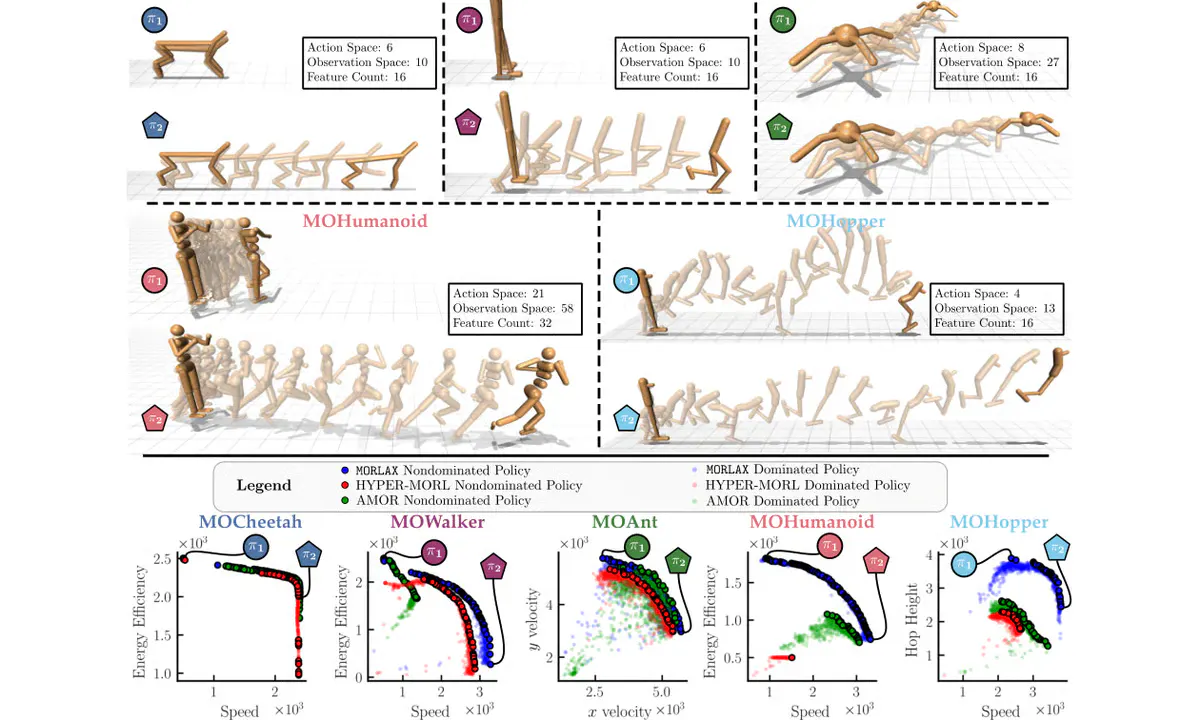
Georgia Tech and ARL release MO-Playground , a JAX-native multi-objective RL toolkit for robotics. New MORLAX algorithm uses hypernetworks mapping trade-off vectors to full policy parameters. Reports 21x to 271x speedups over HYPER-MORL across five MuJoCo benchmarks.